Nederlands
MIT builds thin swimming robot powered by living muscle cells
Researchers at MIT have built a paper-thin swimming robot powered by a layer of living muscle cells. The cells contract when light falls on them, so the robot can be steered. In the lab it has already swum through a small maze.
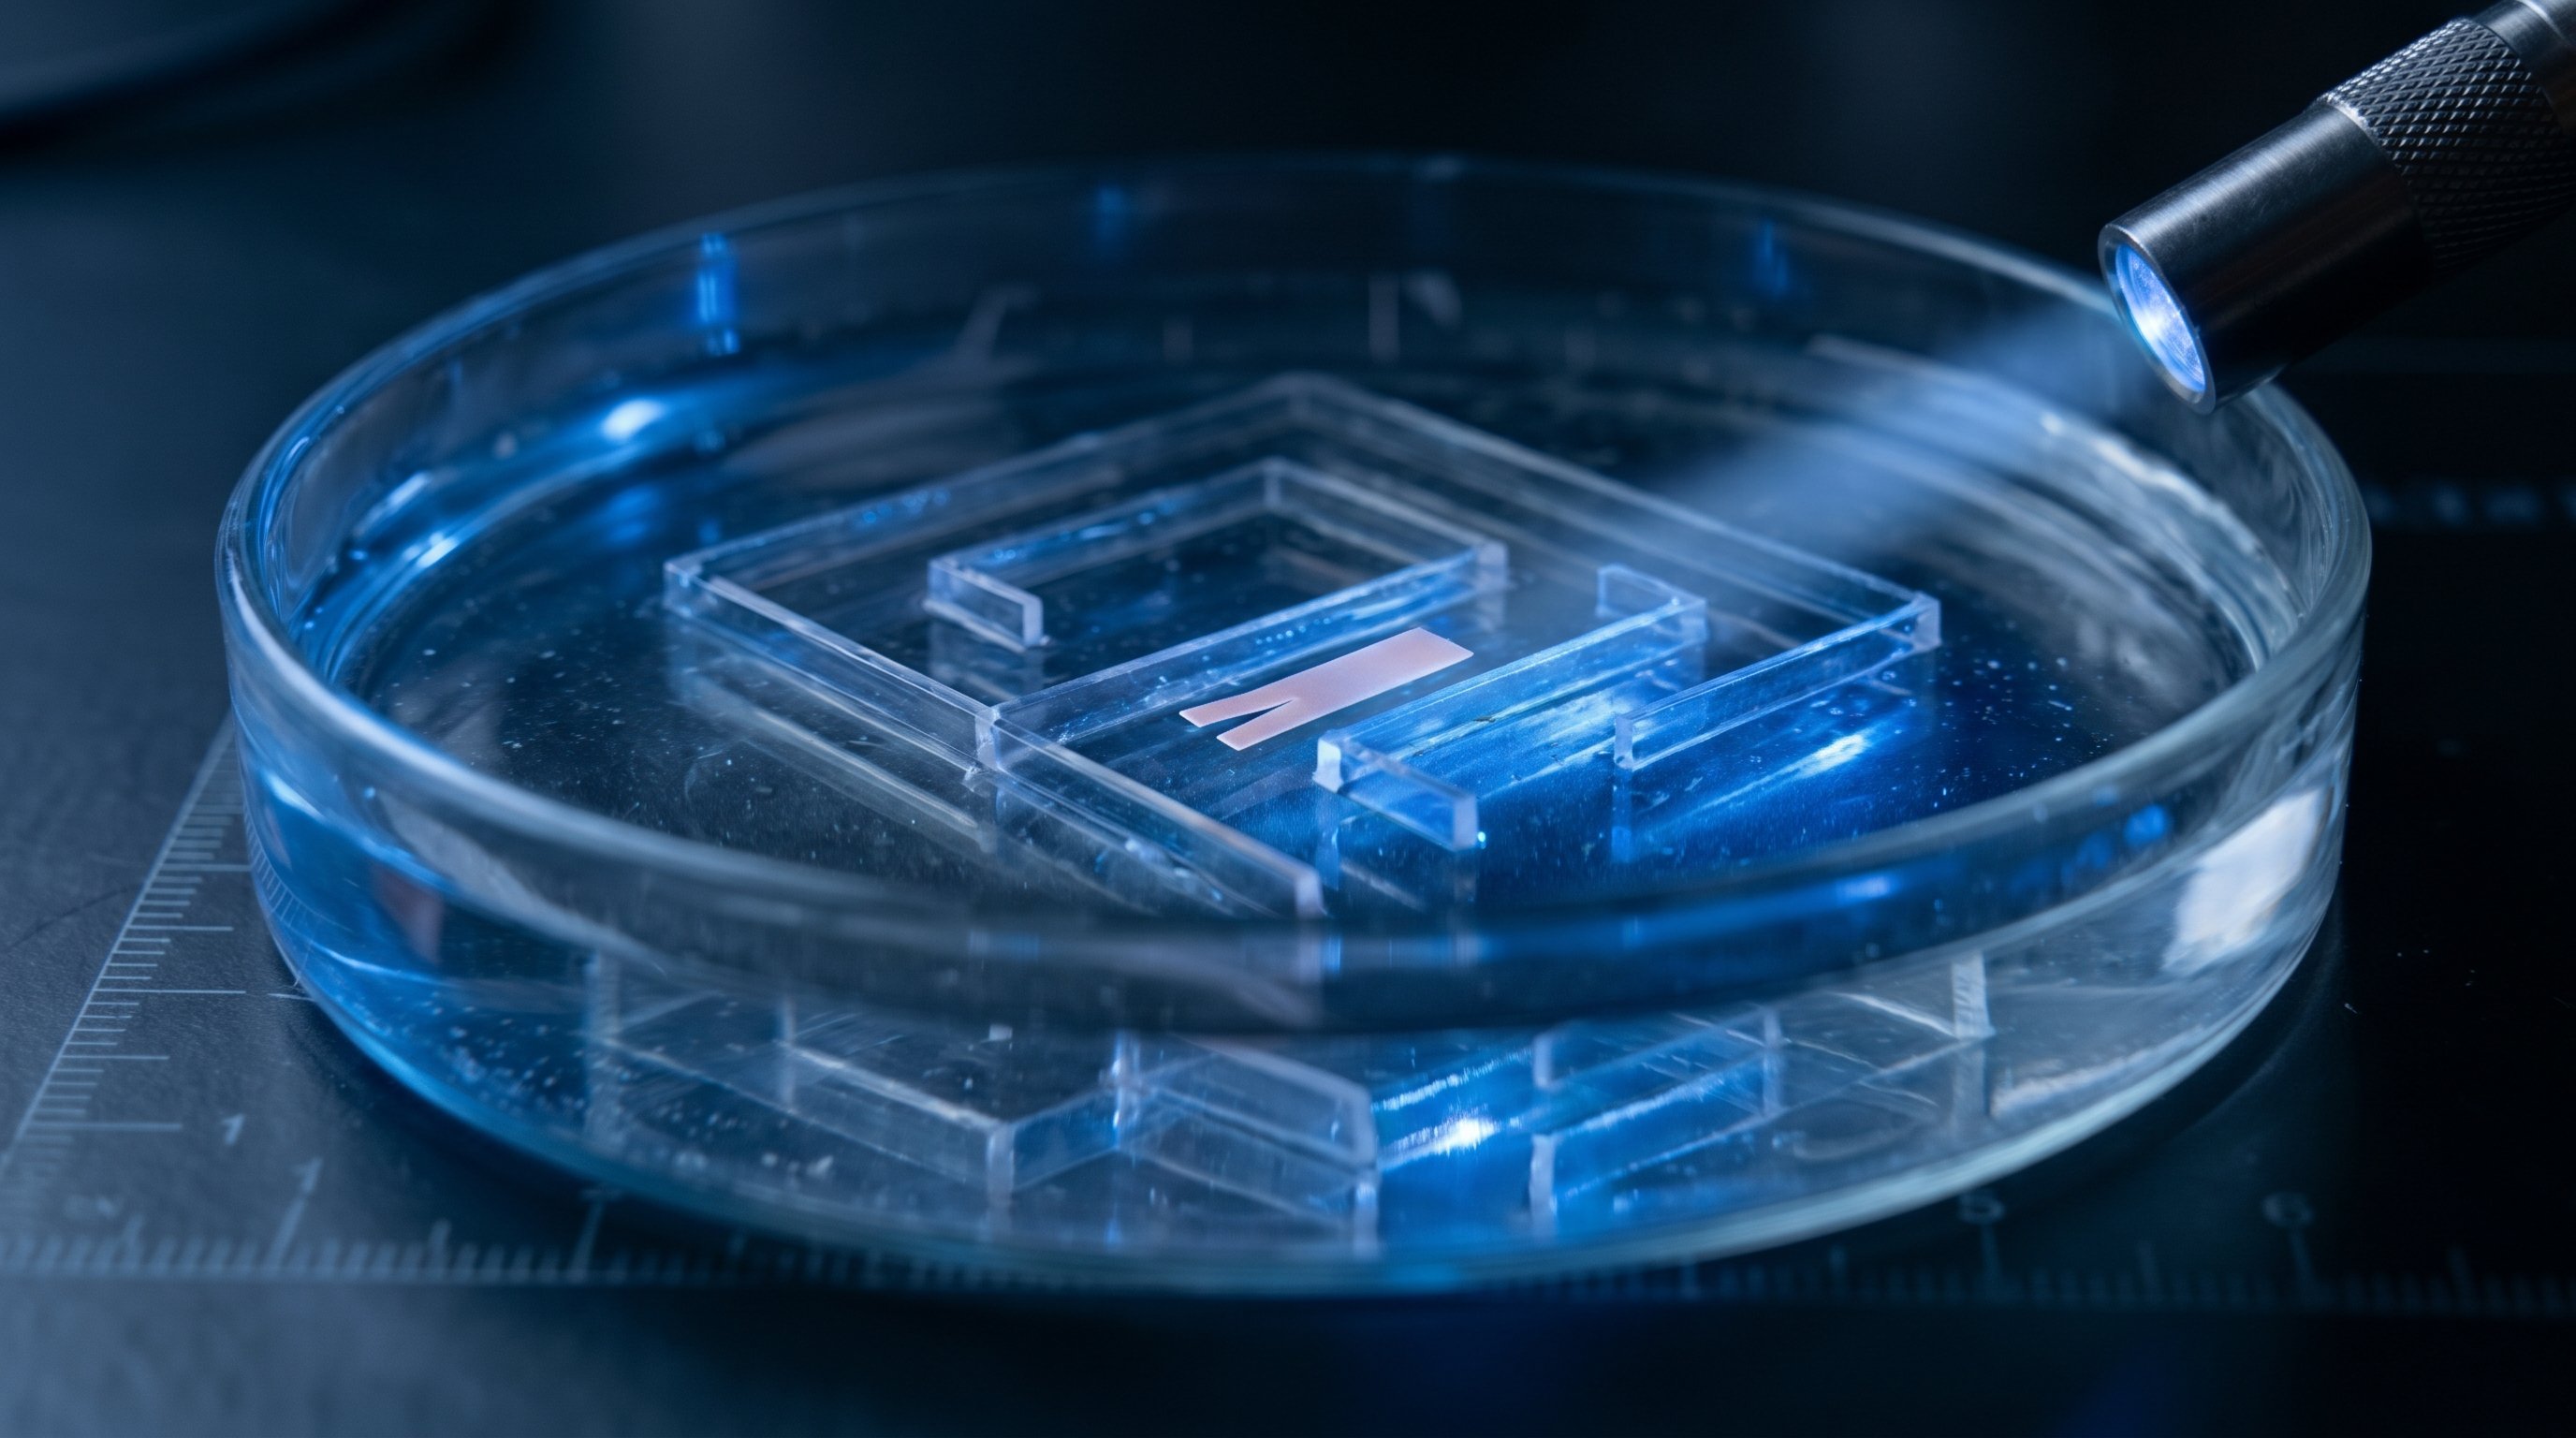
Researchers at the Massachusetts Institute of Technology (MIT) have built a swimming robot that has no motor, but is powered by living muscle cells. They describe the design in the scientific journal Advanced Functional Materials. The first author is PhD student Maheera Bawa; the research took place in the lab of Ritu Raman, associate professor of mechanical engineering. MIT announced the results on 29 September 2026. The research was partly funded by the Office of Naval Research, the research office of the US Navy.
How the robot works
The robot is about the size of a stick of chewing gum. Its 'body' is a thin, flexible layer of gel about half a millimetre thick, with two fins. On each fin grows a layer of muscle cells thinner than a hair. The cells have been genetically modified so that they contract when light falls on them. By flashing light on one fin or the other, the researchers decide how fast the robot swims and which way it goes.
In the lab, they steered the robot this way through a simple underwater maze. At its fastest, it covered about four times its own length per minute. That is slower than an Olympic swimmer, who reaches up to 65 body lengths per minute. According to the researchers, though, the robot is about as fast as a cow shark, a slow shark from the deep sea. Raman points out that moving through water takes much more force than moving through air. For its size, she therefore calls the robot quite strong.
According to the team, this is the first very thin, flat robot that moves using living muscle. Robots with living muscle tissue have existed for some time, but they usually use thick blocks of muscle that need many more cells.
From disc to swimmer
The team built on its own work from last year: a disc of grown muscle, inspired by the iris of the eye. That disc moved a tenth of a millimetre. To get more force, the researchers looked for a better base for the cells. The soft gel they used at first shrank too much when the muscles pulled on it. A stiffer gel worked better: the cells lined up neatly in the same direction and contracted more strongly together. Small grooves in the gel also helped the cells grow in rows, so that together they formed strong muscle fibres.
Before the robot was assembled, the researchers had the muscles 'train' with repeated flashes of light. Just as with people, this made them stronger.
The next step
The current design is deliberately simple: the team wanted to show that a thin layer of muscle delivers enough force to swim. The next step is a body shape that lets the robot go faster. In the long run, Raman sees such soft swimmers doing work in places that are too fragile or too unpredictable for ordinary robots, for example measuring water quality in nature reserves.
What does this mean for the road to the singularity?
Robots do not always have to be made of metal and motors. This research shows that a paper-thin layer of living tissue is already enough to make a robot swim and steer. That opens the way to soft, light machines for fragile environments.
There is also an opportunity for AI here. Finding the best fin shape and the best rhythm of light flashes still takes a lot of trial and error in the lab. AI models that can try out thousands of designs on the computer could speed up that search considerably. What is more, large language models, AI such as ChatGPT, know about the biology of muscles as well as the engineering of robots and the build of fish. That way they can make connections that a single specialist would miss. An AI that designs such a living swimmer and also steers it with light: that is an exciting prospect.
What is the technological singularity? Read the explanation →